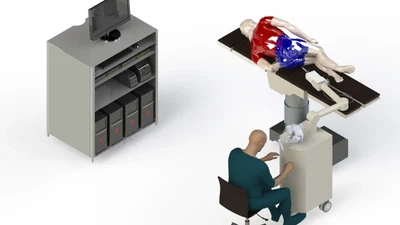
Design and evaluation of a continuum robot with extendable balloons
A novel continuum robot actuated by two extendable balloons, achieving extreme elongation (2000 %) for navigation in long, narrow environments.

Efe Yarbasi is an Assistant Research Scientist in the Engineering Systems Group at the University of Michigan Transportation Research Institute (UMTRI). His research covers the safety of automated and driver-assistance systems and the electrification of transportation. He serves as principal investigator and co-principal investigator on projects sponsored by NHTSA, Toyota Motor North America, and the National Cooperative Highway Research Program. He co-leads the Low Altitude Airspace Working Group at M-Air.
He holds a PhD in Aerospace Engineering from Georgia Tech. There he worked in the Aerospace Systems Design Laboratory under Prof. Dimitri Mavris and developed methods to find and reduce the uncertainties that matter most in complex, multi-disciplinary designs. He is a member of AIAA and IEEE.
Students, please get in touch. I am looking for curious, motivated students to join my research. Projects range from crash analysis and AI for safety to EV charging and low-altitude airspace, and I mentor undergraduate and graduate students. If any of this sounds interesting, send me an email with a short note about your background and what you want to work on.
A novel continuum robot actuated by two extendable balloons, achieving extreme elongation (2000 %) for navigation in long, narrow environments.
Data acquisition, monitoring, and visualization architecture for campus-scale district energy grids at Georgia Tech.
Patent for a flexible robotic medical device for colonoscopy (EP3261517B1, WO2016137417A1).
Master's thesis in Mechanical Engineering at Bogazici University, advised by Assoc. Prof. Evren Samur.